Object & Scene Annotation
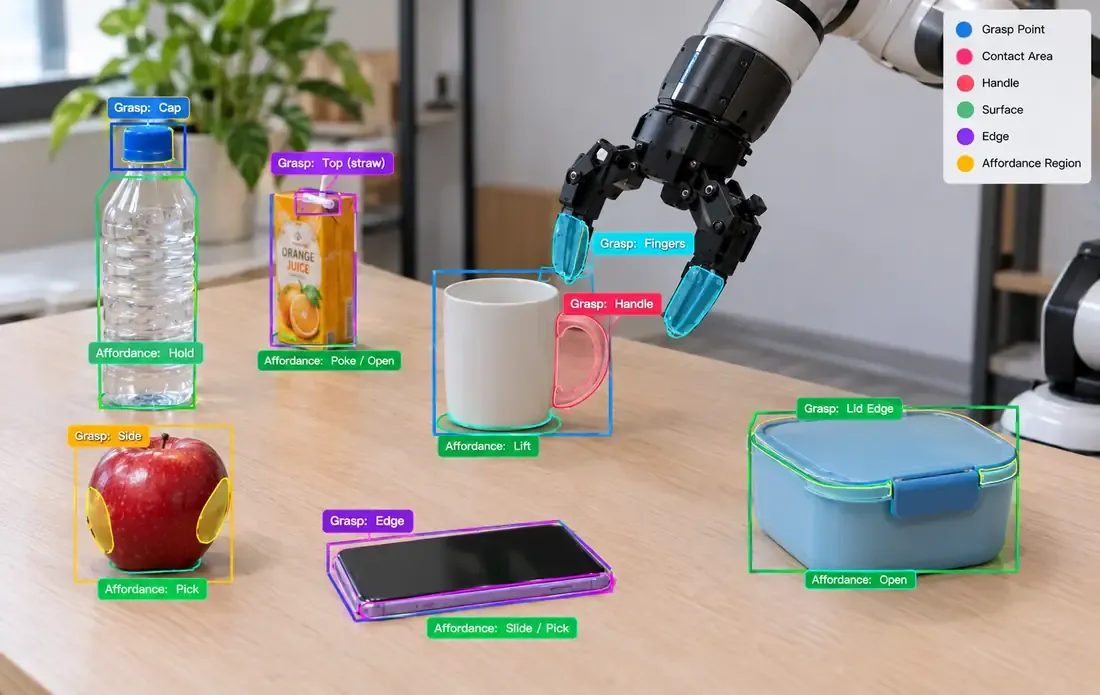
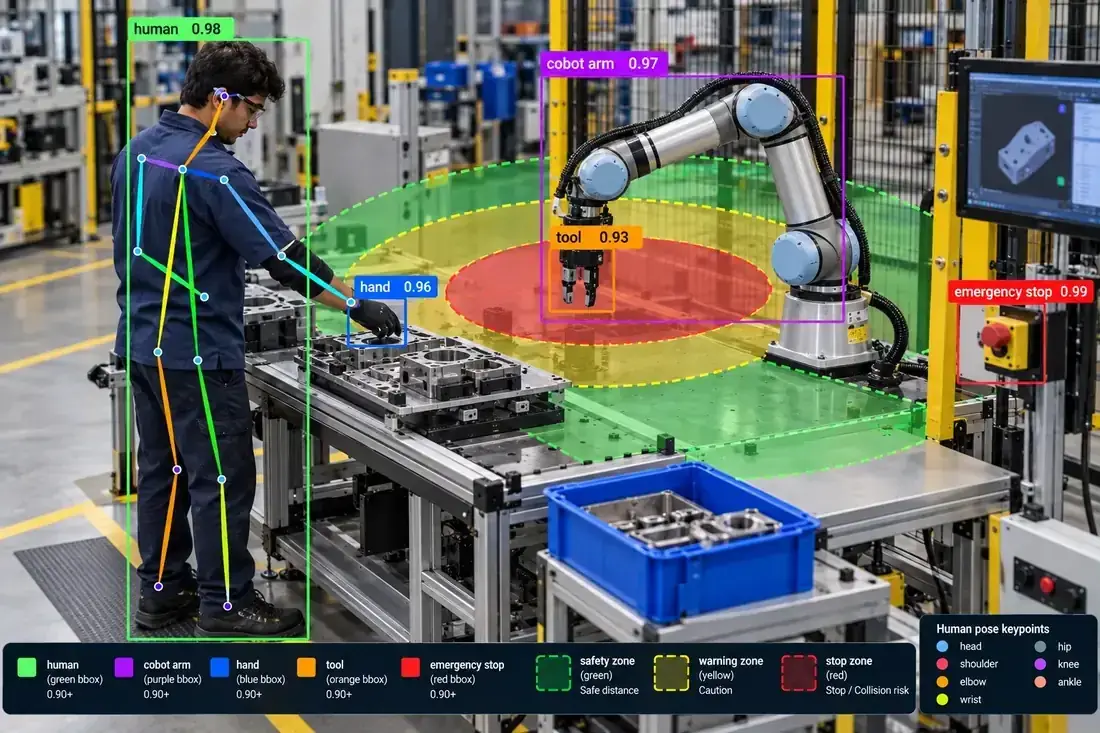
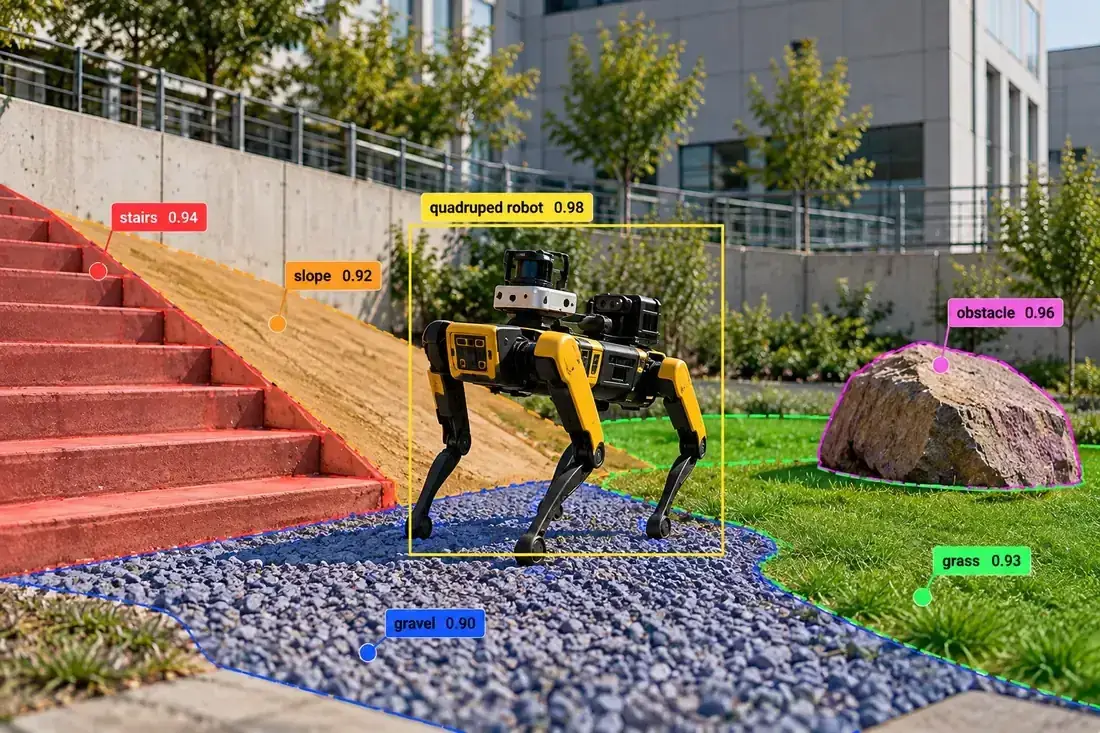
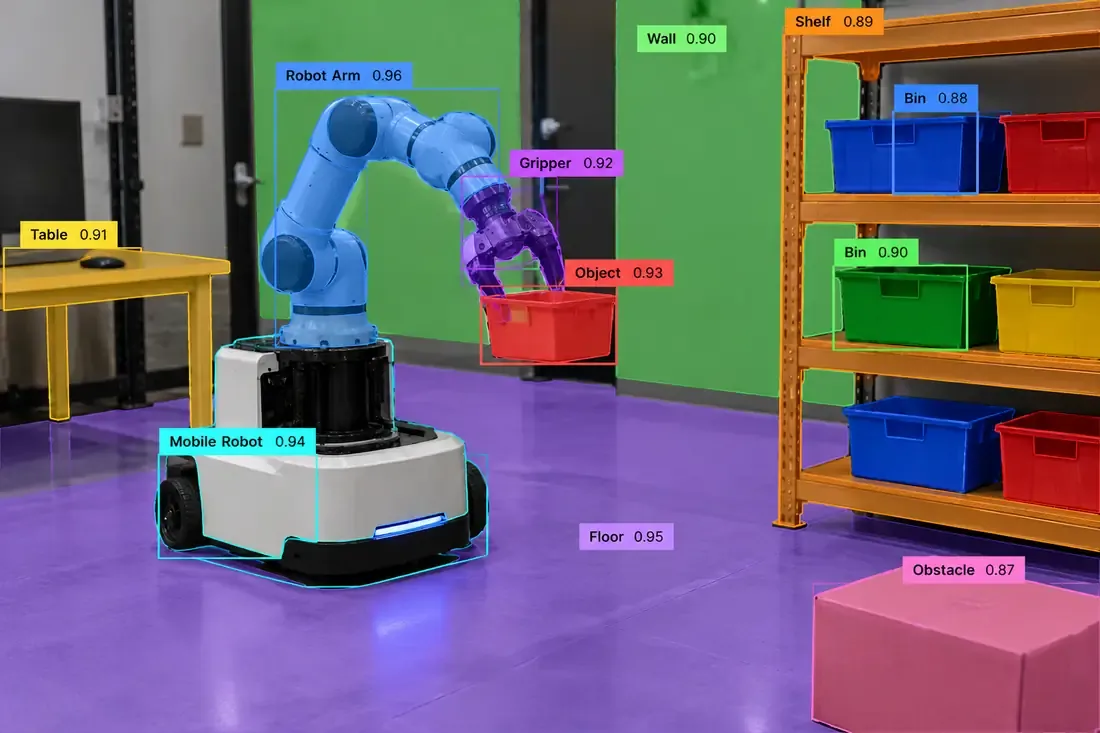
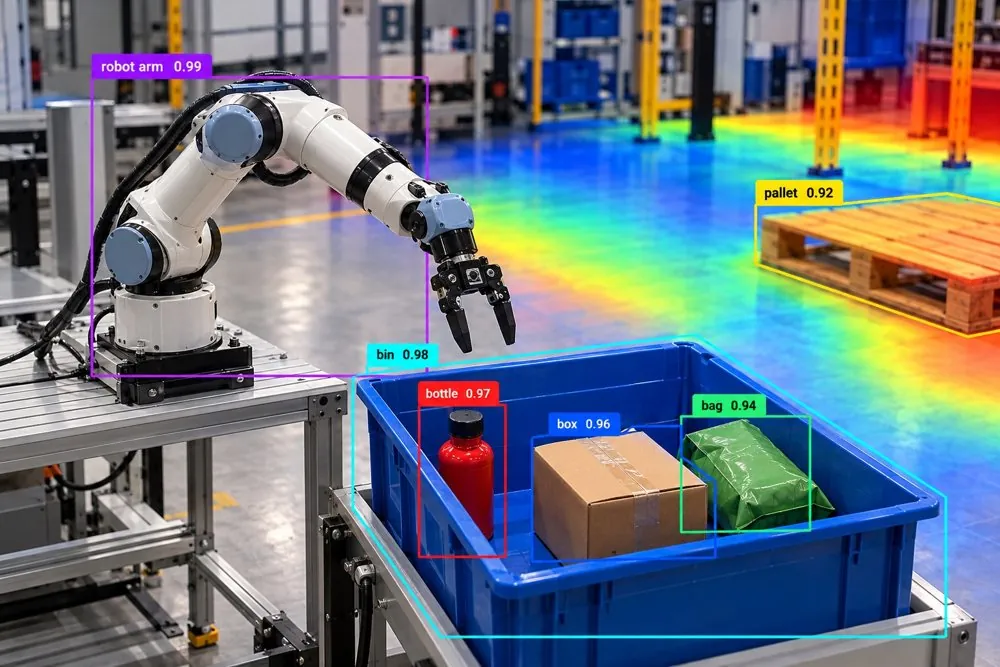
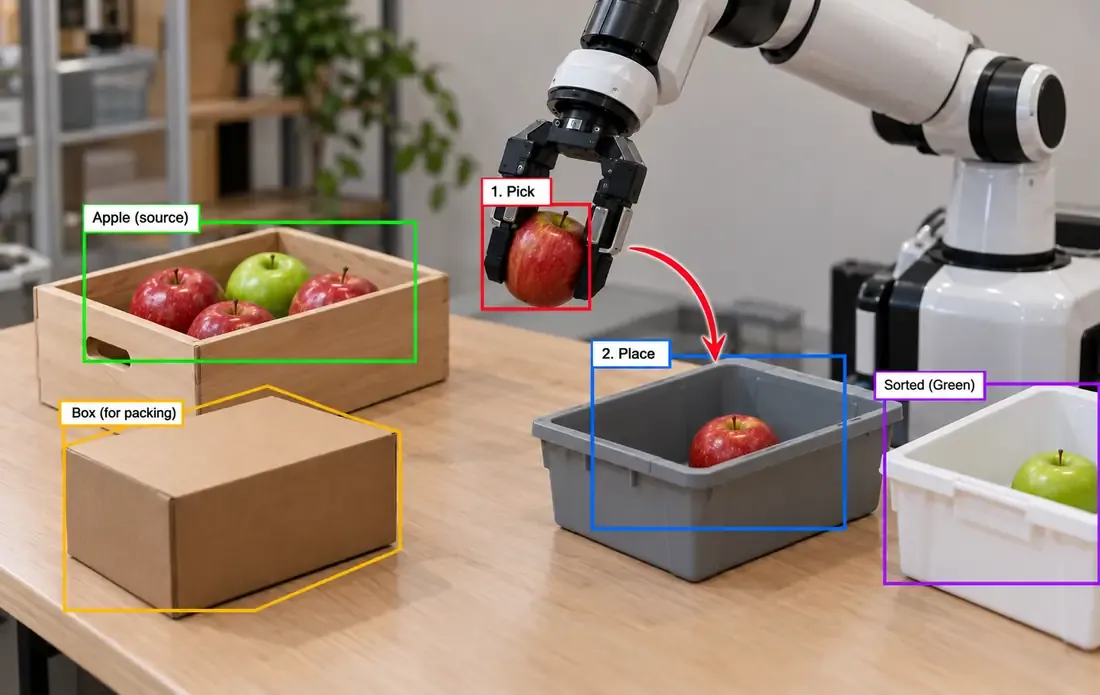
Identifying and localizing objects, tools, equipment, people, and environmental elements around robots using bounding boxes, polygons, and segmentation masks. These datasets support robotic perception, object recognition, navigation, and manipulation.
Robot & Robotic Arm Annotation
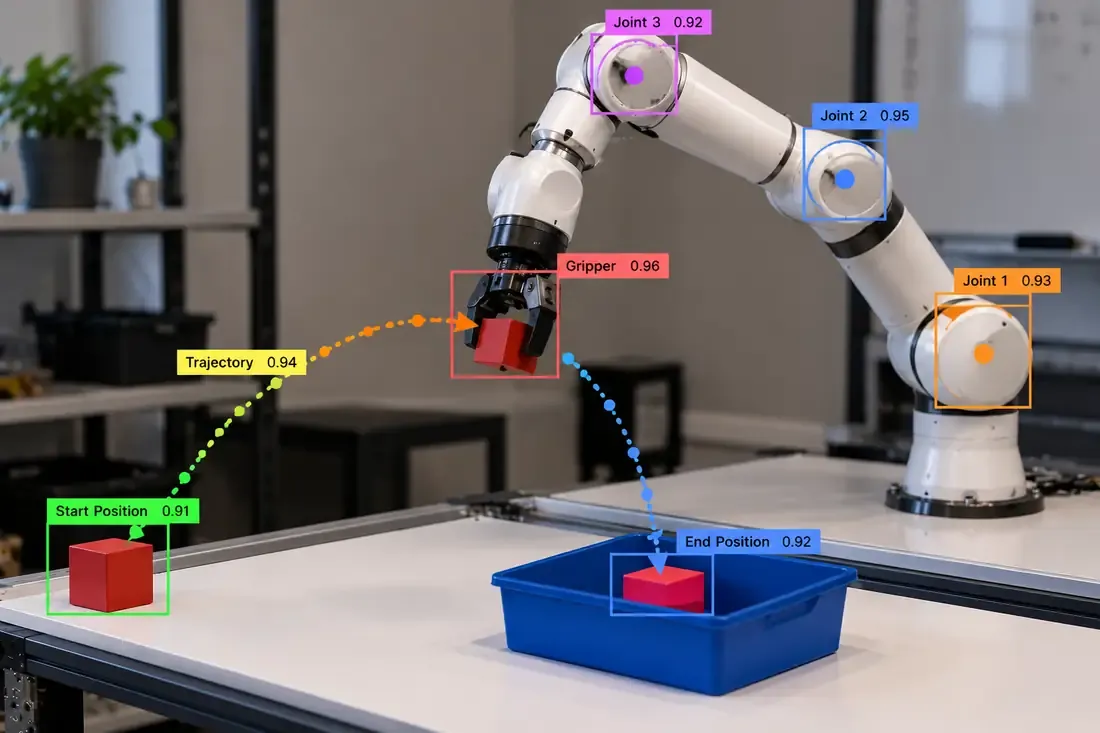
Annotating robotic arms, joints, grippers, end-effectors, mobile robots, humanoid robots, and other robotic systems. These datasets support robot perception, pose estimation, motion analysis, and automation.